GreenWAM Unifies World Modeling and Robot Control
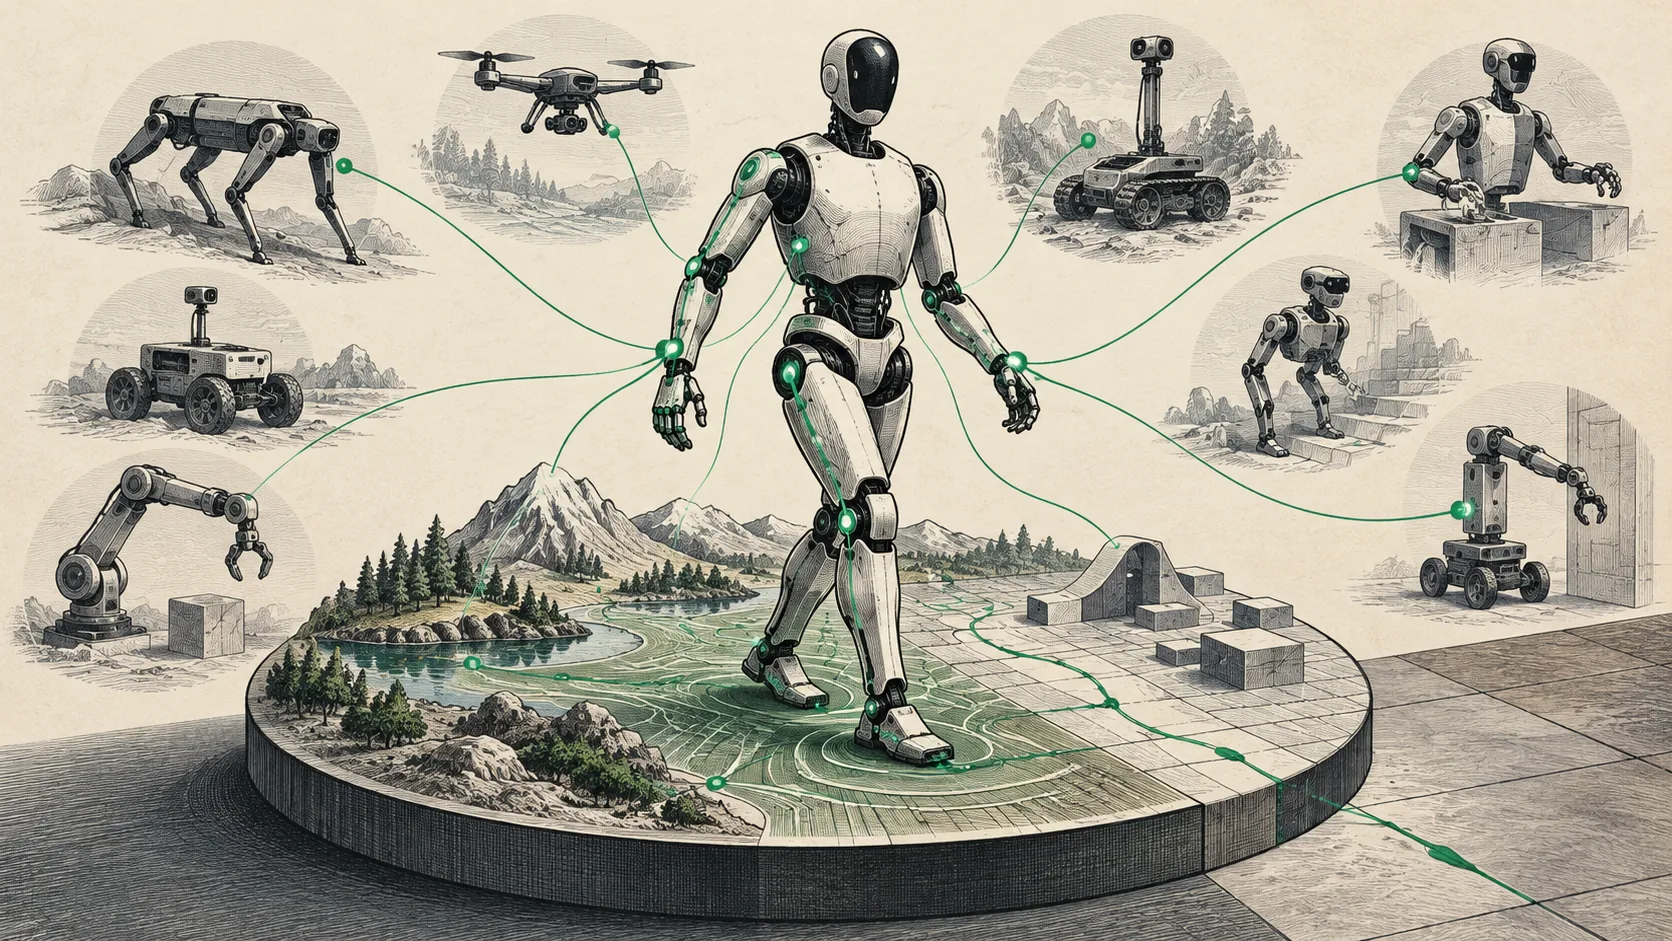
- •Sber Robotics Center researchers presented GreenWAM, a world foundation model designed for robotics.
- •GreenWAM covers 20 robot families and led comparisons on WorldArena 1.0 and zero-shot LIBERO-plus.
- •On a real humanoid, GreenWAM outperformed adapted π0.5 and Cosmos 3 Edge policies more often.
Sber Robotics Center researchers presented GreenWAM, a robotics world foundation model, in a paper published on October 13. The model is designed to predict how a robot’s actions change its surroundings and to choose actions across different robot bodies, roles and action-recording formats.
GreenWAM uses a shared anatomical action space covering 20 robot families, from bimanual arms to dexterous humanoids. The researchers jointly trained it on those families in visual, action-conditioned and world-action modes, and designed policies that separate an action expert from the generator.
On WorldArena 1.0, GreenWAM achieved top-tier trajectory, depth and 3D accuracy, outperforming every world-action model and video generator in the researchers’ comparison. As a policy, it ranked among the top entries on the RoboTwin 2.0 leaderboard, achieved the highest zero-shot LIBERO-plus success among the compared methods, and was competitive on CALVIN and LIBERO.
The team also adapted GreenWAM to a real humanoid, where it succeeded more often than policies adapted from π0.5 and Cosmos 3 Edge. They distilled it into a single-step policy for real-time control. Controlled experiments found that robot specialization improved world prediction and control together; separating an action expert at the start of adaptation helped; and retaining world-model modes during policy adaptation preserved robustness to scene changes.